Research
Georgia Tech CRAB Lab
The CRAB Lab at Georgia Tech researches complex rheology and biomechanics.
I worked on the biped robot, researching its interactions with granular slopes and designing actuated cleats for the biped. The work with cleat actuation is still currently an ongoing project.
Research
Granular Terrain Interaction
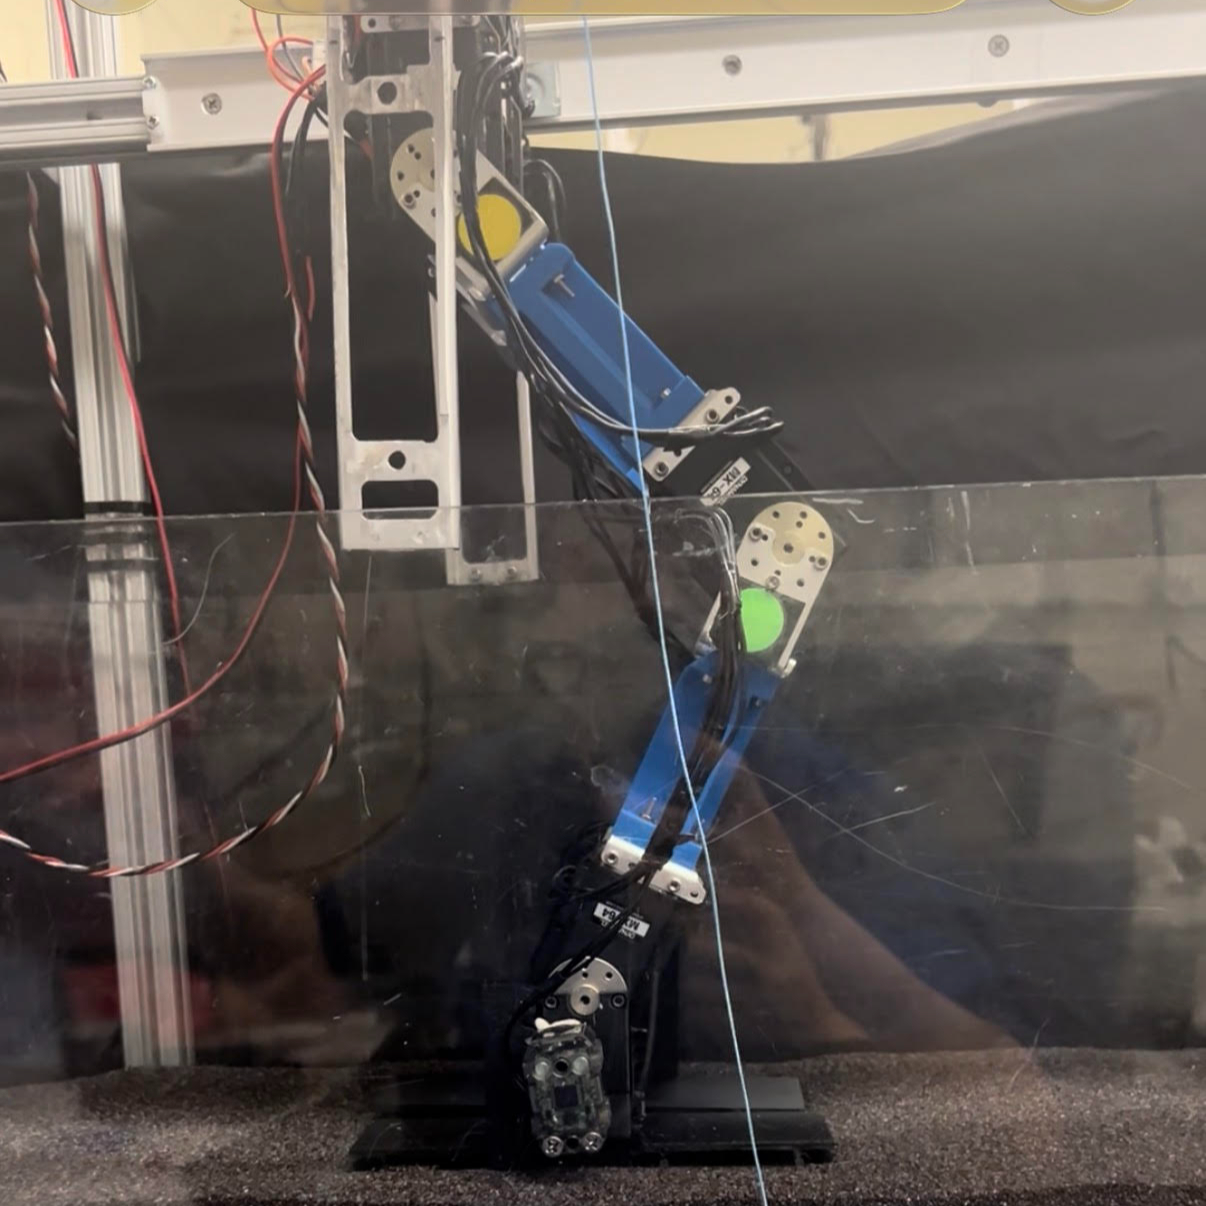
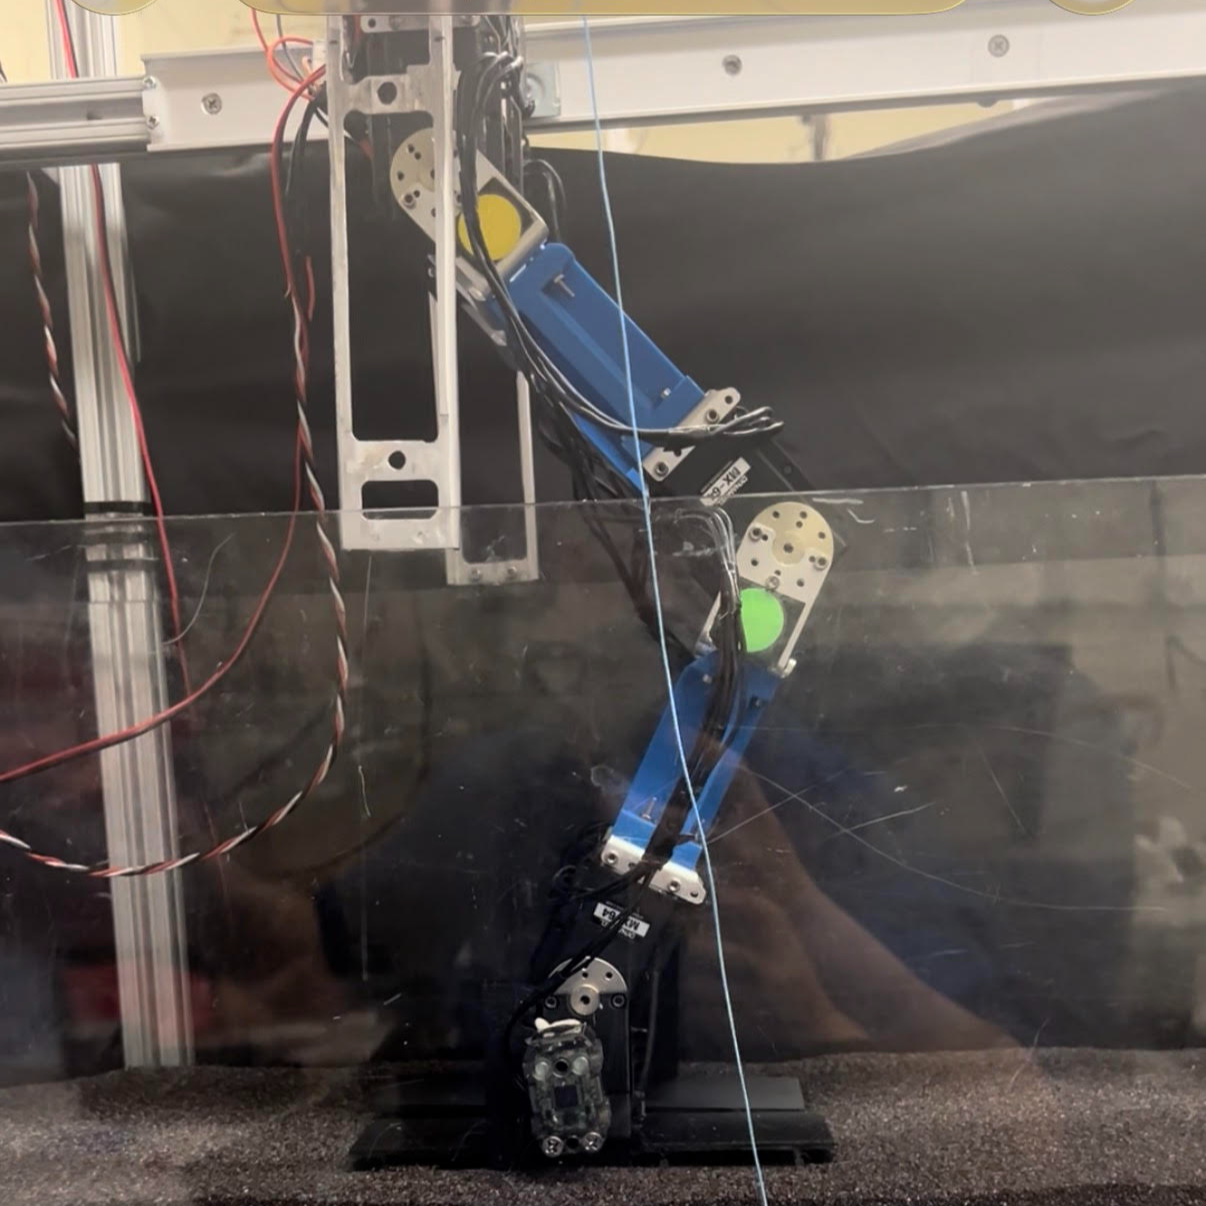
- Bipedal robotics often uses feedback controls to generate gaits for motion
- On granular surfaces, and especially at slopes, these methods no longer work as the surface can, and often does, deform
- Thus, robots need to either change their gait construction to account for the sudden changes in terrain or use mechanical methods to prevent slips
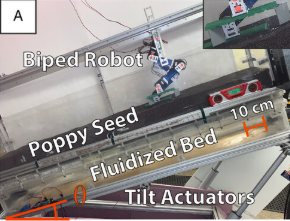
- The experimental setup includes the bipedal robot and tilting fluidized bed using poppy seeds as the granular material
- Using wide, flat feet, the robot was able to successfully navigate slight slopes (±10°), but started to fail beyond that
- After introducing cleats to help stability, performance improved with the robot successfully navigating extreme slopes (±30°) while using the same walking gait